A change of basis is a method to convert vector coordinates with respect to one basis to coordinates with respect to another basis.
Consider a vector u with reference to orthogonal unit basis vectors x1, x2 and x3.
$$\textbf{u}=px_1+qx_2+rx_3\; \; \; \; \; \; \; (1)$$
where p, q and r are the scalar components of the unit basis vectors x1, x2 and x3 respectively.
Clearly,
$$p=\textbf{u}\cdot x_1\; \; \; \; q=\textbf{u}\cdot x_2\; \; \; \; r=\textbf{u}\cdot x_3\; \; \; \; (2)$$
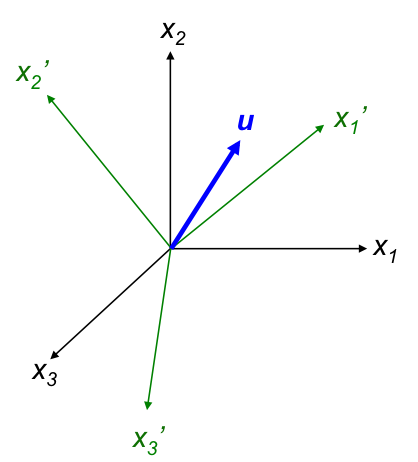
If we define u with respect to another orthogonal reference frame with unit basis vectors x’1, x’2 and x’3 (see above diagram), we have:
$$\textbf{u}=p^{\prime} x^{\prime}_1+q^{\prime}x^{\prime}_2+r^{\prime}x^{\prime}_3\; \; \; \; (3)$$
and
$$p^{\prime}=\textbf{u}\cdot x^{\prime}_1\; \; \; \; q^{\prime}=\textbf{u}\cdot x^{\prime}_2\; \; \; \; r^{\prime}=\textbf{u}\cdot x^{\prime}_3\; \; \; \; (4)$$
To find the relationship between the two reference frames, we substitute eq1 in eq4 to give
$$p^{\prime}=\left ( px_1+qx_2+rx_3 \right )\cdot x^{\prime}_1=px_1\cdot x^{\prime}_1+qx_2\cdot x^{\prime}_1+rx_3\cdot x^{\prime}_1\; \; \; \; \; \; \; (5)$$
$$q^{\prime}=\left ( px_1+qx_2+rx_3 \right )\cdot x^{\prime}_2=px_1\cdot x^{\prime}_2+qx_2\cdot x^{\prime}_2+rx_3\cdot x^{\prime}_2\; \; \; \; \; \; \; (6)$$
$$r^{\prime}=\left ( px_1+qx_2+rx_3 \right )\cdot x^{\prime}_3=px_1\cdot x^{\prime}_3+qx_2\cdot x^{\prime}_3+rx_3\cdot x^{\prime}_3\; \; \; \; \; \; \; (7)$$
Since the dot product of two vectors gives a scalar, we can write eq5, eq6 and eq7 as
$$p^{\prime}=a_{11}p+a_{12}q+a_{13}r$$
$$q^{\prime}=a_{21}p+a_{22}q+a_{23}r$$
$$r^{\prime}=a_{31}p+a_{32}q+a_{33}r$$
which can be expressed in the following matrix equation:
$$\begin{pmatrix} p^{\prime}\\ q^{\prime}\\ r^{\prime} \end{pmatrix}=\begin{pmatrix} a_{11} &a_{12} &a_{13} \\ a_{21} & a_{22} &a_{23} \\ a_{31} &a_{32} & a_{33} \end{pmatrix}\begin{pmatrix} p\\ q\\ r \end{pmatrix}\; \; \; \; \; \; \; (8)$$
where \(a_{ij}=x^{\prime}_i\cdot x_j=\left | x^{\prime}_i \right |\left | x_j \right |cos\theta_{x^{\prime}_i,x_j}=cos\theta _{x^{\prime}_i,x_j}\).
The matrix containing aij is known as the change of basis matrix . We can rewrite eq8 as:
$$u^{\prime}_i=\sum_{j=1,2,3}a_{ij}u_j\; \; \; \; \; \; \; (9)$$
where \(u^{\prime}_1=p^{\prime},u^{\prime}_2=q^{\prime},u^{\prime}_3=r^{\prime}\) and \(u_1=p,u_2=q,u_3=r\).
Eq9 is often written as a short form by omitting the summation symbol:
$$u^{\prime}_i=a_{ij}u_j\; \; \; \; \; \; \; (10)$$
For example, the change of basis from the orthogonal basis xj to the orthogonal basis x’i as a rotation about the x3-axis, where x3 coincides with x’3 (x’3 = x3 and is perpendicular to the plane of the page), is depicted as:
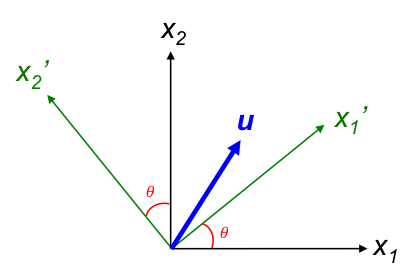
To determine the change of basis matrix, we have
$$x^{\prime}_1\cdot x_3=x^{\prime}_3\cdot x_1=x^{\prime}_2\cdot x_3=x^{\prime}_3\cdot x_2=cos90^o=0$$
$$x^{\prime}_3\cdot x_3=cos0^o=1$$
$$x^{\prime}_1\cdot x_1=x^{\prime}_2\cdot x_2=cos\theta$$
$$x^{\prime}_1\cdot x_2=cos\left ( 90^o-\theta \right )=sin\theta$$
$$x^{\prime}_2\cdot x_1=cos\left ( 90^o+\theta \right )=-sin\theta$$
Therefore,
$$a_{ij}=\begin{pmatrix} a_{11} & a_{12}&a_{13}\\ a_{21}& a_{22}&a_{23}\\ a_{31}& a_{32}& a_{33}\end{pmatrix}=\begin{pmatrix} x^{\prime}_1\cdot x_1 & x^{\prime}_1\cdot x_2&x^{\prime}_1\cdot x_3\\ x^{\prime}_2\cdot x_1&x^{\prime}_2\cdot x_2 &x^{\prime}_2\cdot x_3\\ x^{\prime}_3\cdot x_1& x^{\prime}_3\cdot x_2& x^{\prime}_3\cdot x_3\end{pmatrix}=\begin{pmatrix} cos\theta &sin\theta &0 \\ -sin\theta & cos\theta &0 \\ 0 &0 &1 \end{pmatrix}\; \; \; \; \; \; \; (12)$$
Consider again the vector u with reference to a coordinate system that is defined by the orthogonal unit basis vectors x1, x2 and x3 (see diagram below).
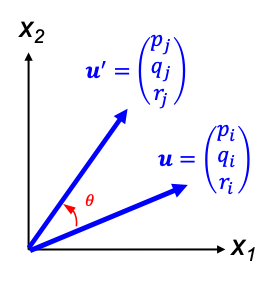
The rotation of u with respect to this fixed coordinate system is expressed as:
$$\begin{pmatrix} p_j\\ q_j\\ r_j \end{pmatrix}=\begin{pmatrix} cos\theta &-sin\theta &0 \\ sin\theta & cos\theta &0 \\ 0 &0 & 1 \end{pmatrix}\begin{pmatrix} p_i\\ q_i\\ r_i \end{pmatrix}\; \; \; or\; \; \; \; \boldsymbol{u^{\prime}}=R\boldsymbol{u}$$
Compared to the change of basis of u that was described earlier, the rotation matrix R is the transpose of the change of basis matrix. Alternatively, the rotation of u by θ can be perceived a change of basis, with the coordinate system rotated by –θ. This implies that we can analyse a problem in two ways.
Question
Show that the reverse transformation of \(V=MU\) is given by \(U=M^TV\), where \(U\) and \(V\) are matrices containing three mutually orthogonal unit basis vectors.
Answer
The three unit basis vectors are mutually orthogonal, where \(\boldsymbol{u}_i\cdot\boldsymbol{u}_j=\boldsymbol{u}_i^T\boldsymbol{u}_j=\delta_{ij}\). Similarly, the transformed unit basis vectors are mutually orthogonal: \(\boldsymbol{v}_i^T\boldsymbol{v}_j=\delta_{ij}\). Substituting \(\boldsymbol{v}_i=M\boldsymbol{u}_i\) into the latter expression gives \((M\boldsymbol{u}_i)^T(M\boldsymbol{u}_j)=\delta_{ij}\). Using the matrix property \((AB)^T=B^TA^T\),
$$\boldsymbol{u}_i^T(M^TM)\boldsymbol{u}_j=\delta_{ij}$$
This condition holds for all \(i\) and \(j\) only if \(M^TM=I\), implying that \(M^T=M^{-1}\), which is the defining property of an orthogonal matrix. Since the forward transformation is given by \(V=MU\), multiplying both sides by \(M^{-1}\) gives \(M^{-1}V=M^{-1}MU\) or \(U=M^{-1}V\). Substituting \(M^{-1}=M^T\) results in the reverse transformation: \(U=M^TV\).